The Modular Design System For Flexible Gripping
In the last years we developed tailor-made solutions for our customers including hygienic design, detectability and rapid adjustment of the gripper in one End of Arm Tooling (EoAT)-device were the result. This customer oriented working routine guarantees the best possible solution. Inspire us with your challenges!
SoftGripper
The grippers for high-speed and cobot applications.
SoftGripping fingers are universal and can be used with any object shape. Primary, SoftGrippers are used in any task involving pick&place using:
- High-speed delta robots
- Scara robots
- Cobots with human interaction
The inherintly superior hygienic design makes cleaning especially easy. For special applications, like handling raw or prepared meats, fish or bakery products, SoftGripper bases are available in special FDA certified coating. This way, cleaning the gripper in a machine or by applying cleaning solutions.
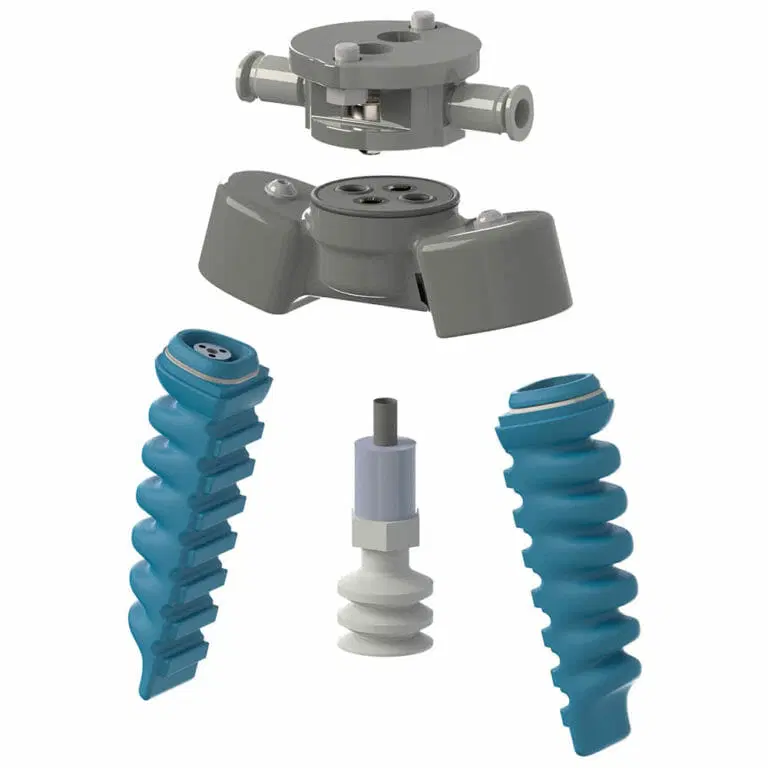
SoftGripper Elements
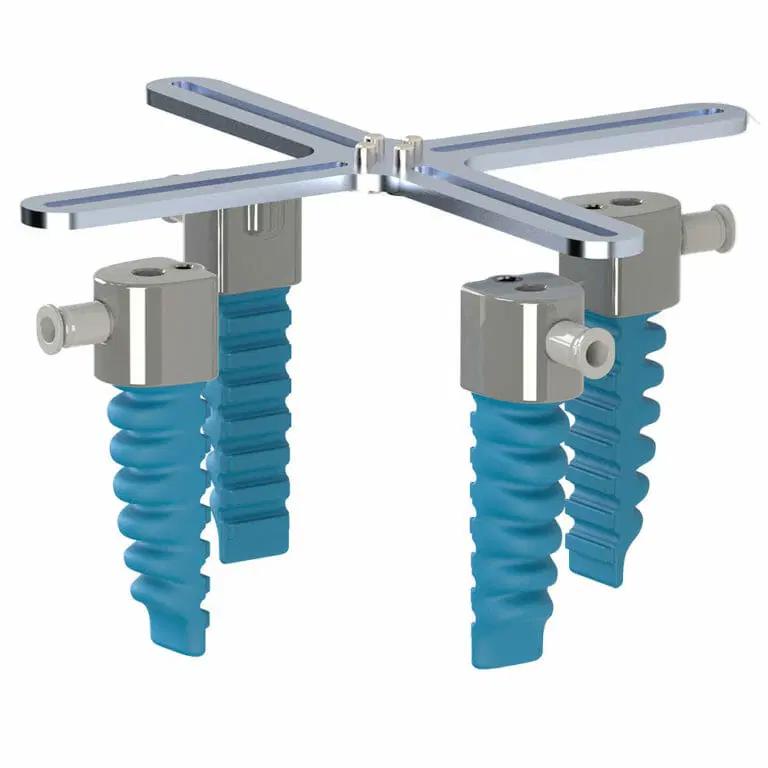
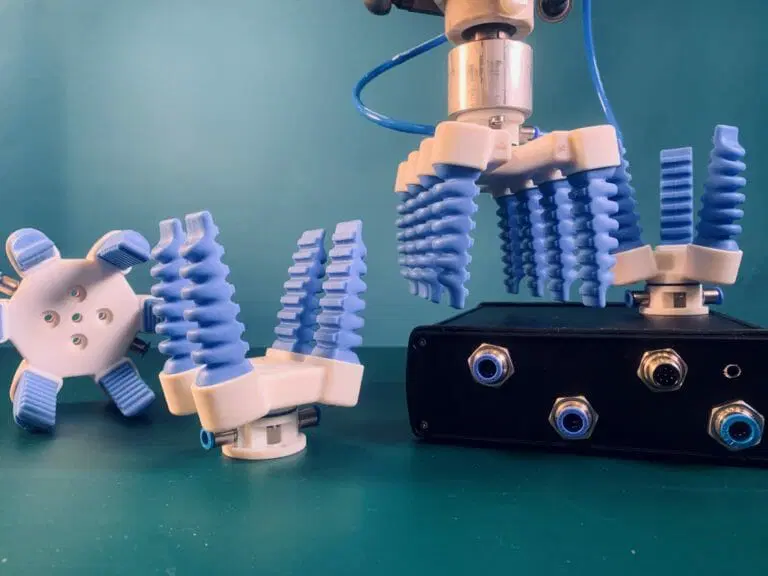
SoftGrippers are modular. They are made up of multiple elements like: Flange adapter, base, fingers and optionally spacer and suction cup.
- Flange and Base: A flange adapter is needed to mount the gripper to the robot. Adapters are available for any robot on the market. The shape of the gripping object determines the base, which is an essential part of the gripper. A circular object needs a centric base, a cubic or long object a parallel one. We offer different types of bases with various number of fingers and different angles. Optionally, our SoftGripping bases are designed according hygienic requirements and can be delivered with a FDA-approved coating.
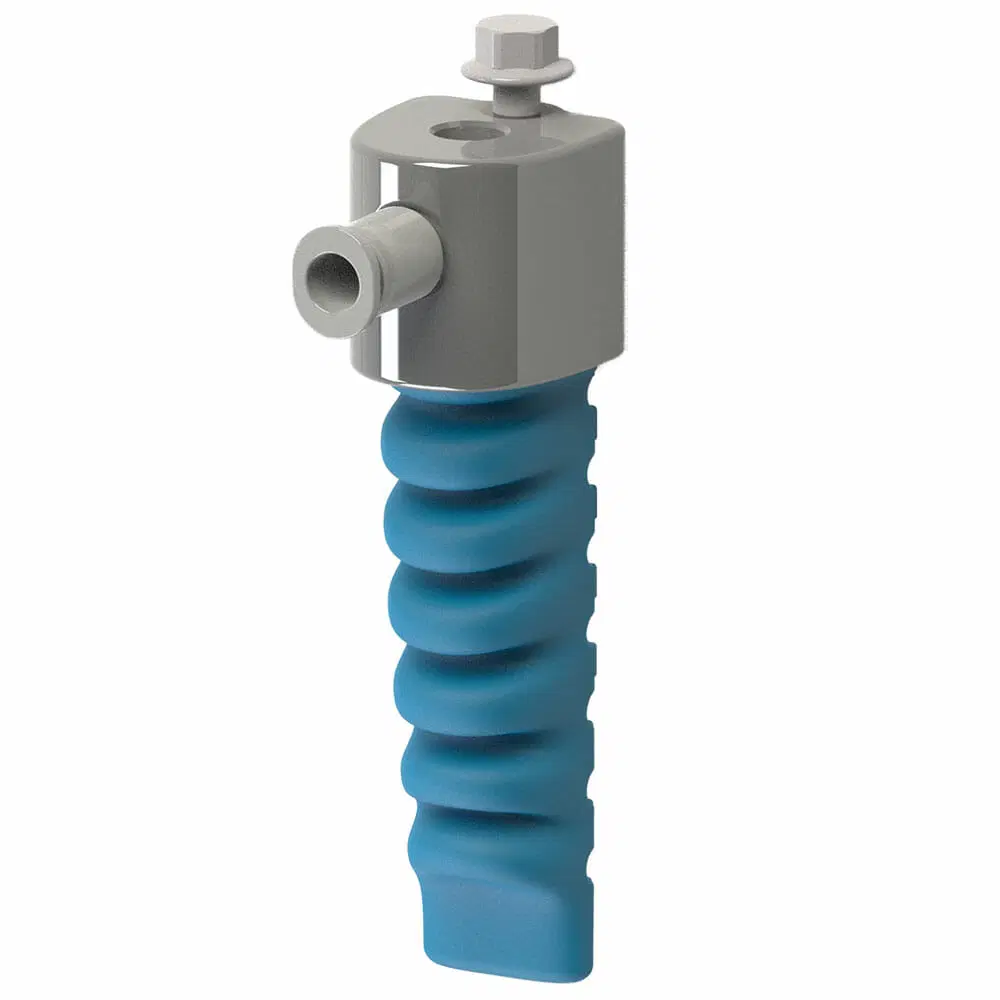
- Fingers: The core of our grippers are the fingers. They adapt to the shape of any object without damaging the surface. The main advantages are the low weight, the speed and the capability to work with all kinds of food. Our pneumatically driven fingers are made of FDA-approved silicon rubber.
- Spacers and Suction cups: Suction cups can be used to support the fingers. This is especially useful for bin picking, or when you need additional stabilization of the object. For additional precision and to prevent the goods from sliding up, spacers can be used instead of the suction cup. Or you can use the mount for other tools.
SoftActuator
SoftActuators for your Own High Speed Pick And Place Gripper.
SoftActuators are made to be used:
- For engineers who wants to build their own Gripper
- For a huge variety of objects
- For easy adjustment when the gripping objects change
- In setups for easy prototyping
We provide the SoftActuators, you choose the shape of your base. You can freely choose the type of your base with aluminum construction profiles or a bended plate. Our proven pneumatically driven fingers are made of FDA-approved silicon rubber and can be mounted on every EoAT setup in hygienic design and materials.
Types of SoftActuators:
- 1-Finger SoftActuator
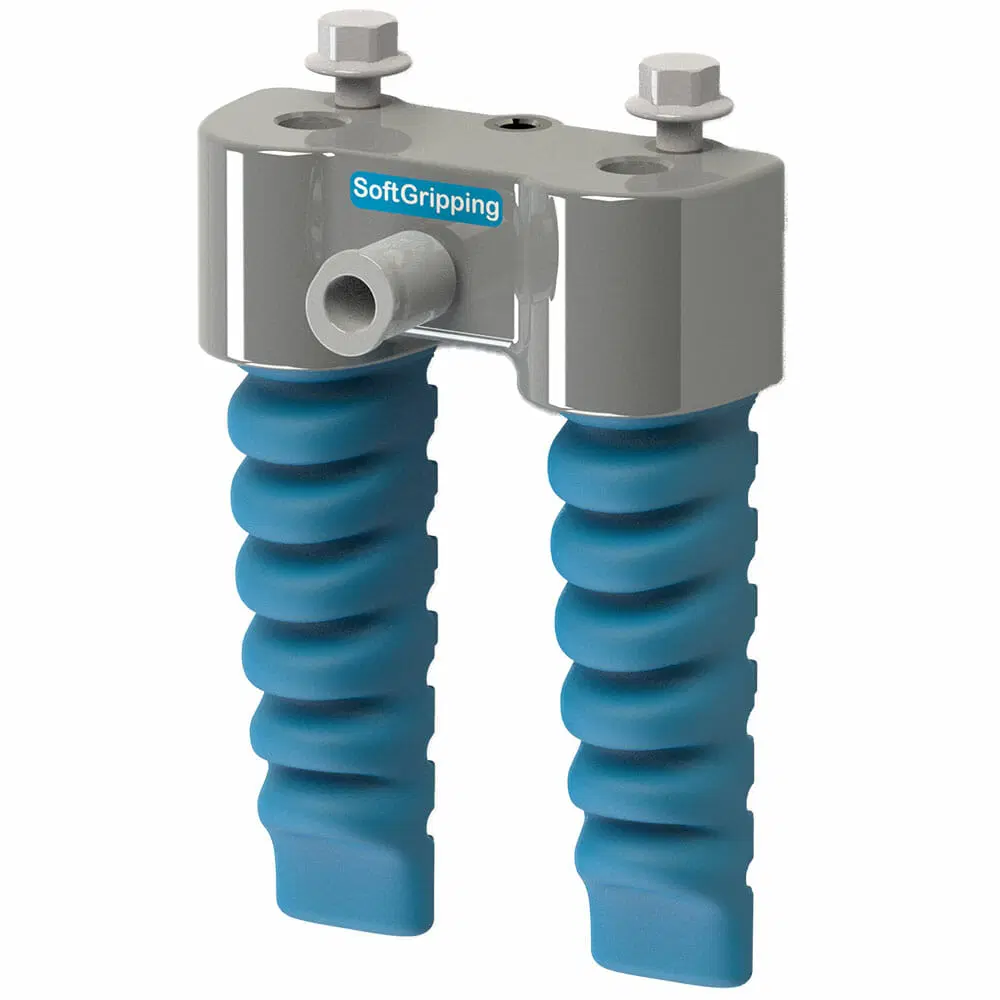
- 2-Finger SoftActuator
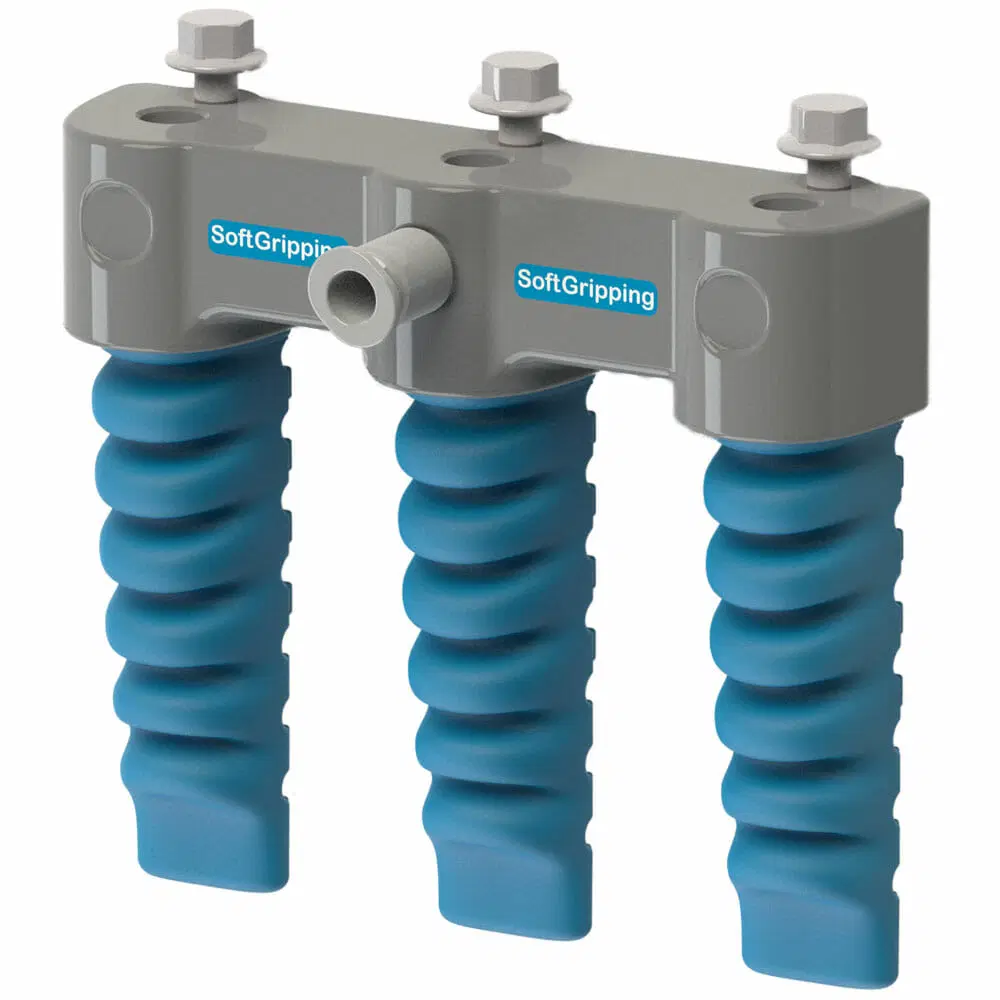
- 3-Finger SoftActuator
If you need something special like 4, 5, 6, 7, … fingers or actuators with a larger or smaller finger distance, we´ll build it for you within 2 weeks.